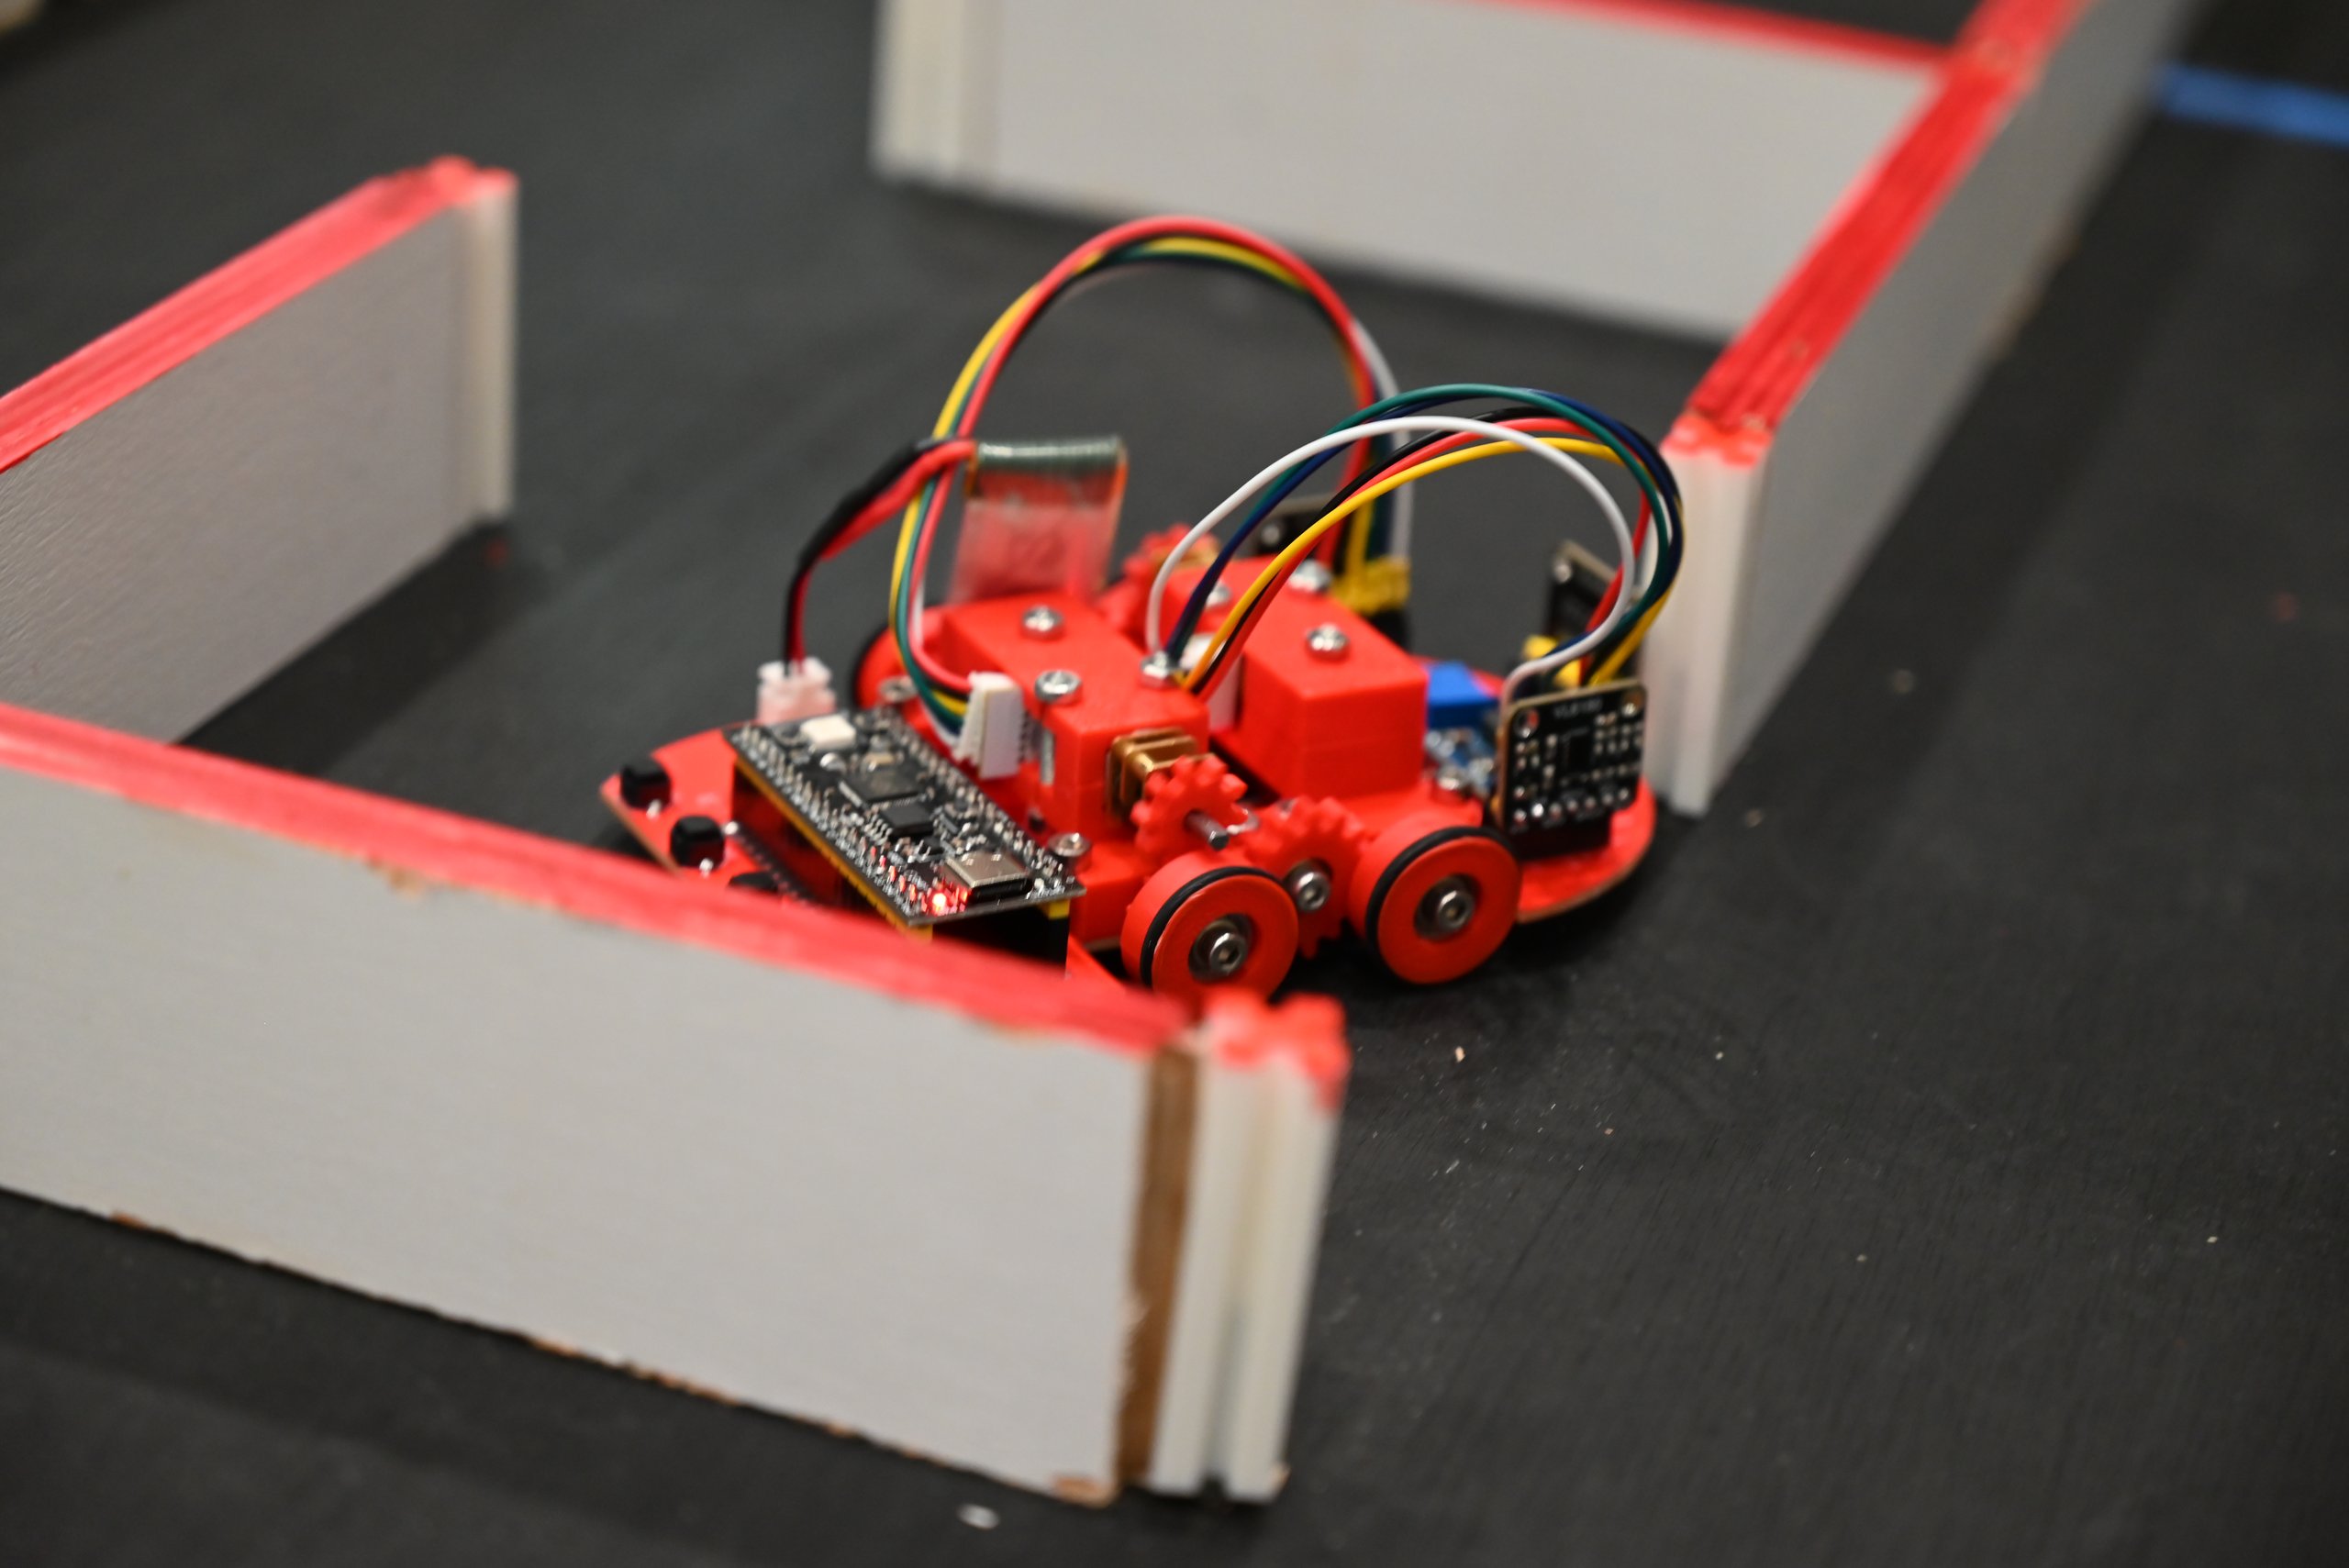
Learn how to give your MicroMouse robot a sense of its surroundings!
We’ll cover the following topics:
🚶♂️ Moving your robot through the maze one square at a time using IMUs and encoders
🏰 Wall hugging: a basic way to solve some mazes
🗺️ Building a map of the maze using the Time-of-Flight sensors
Sign-up here 👉 https://rsadelft.nl/swarming